|
Parameter |
Short-Reach Version |
Long-Reach Version |
|
Number of axes |
6 |
6 |
|
Reach |
922 mm |
1,400 mm |
|
Payload |
5 kg |
10 kg |
|
Repeatability |
±0.02 mm |
±0.05 mm |
|
Workpiece feeding / tray type |
Grid-pattern tray |
Grid-pattern tray |
|
Number of trays |
2 |
2 |
|
Tray dimensions |
420 × 500 mm |
420 × 680 mm |
|
Overall dimensions (L × W) |
1,480 × 650 mm |
1,890 × 750 mm |
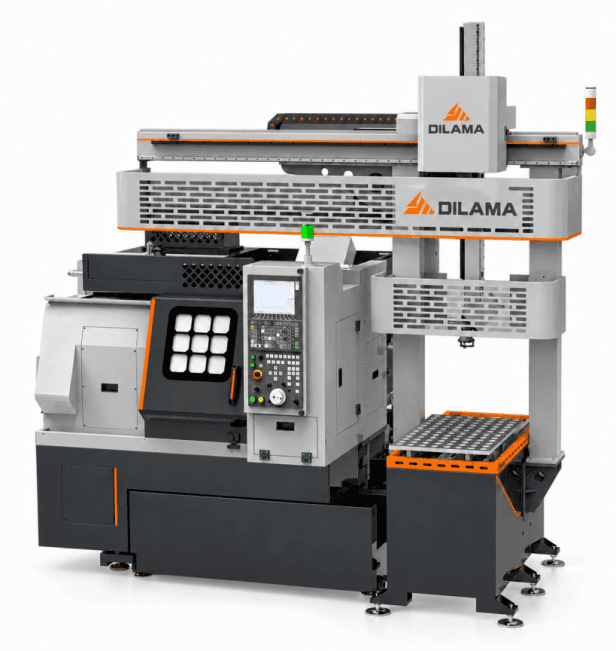
An integrated workstation combining a six-axis robot, force control system, vision-guided flexible trays, and a mobile base.
With human-robot collaborative safety as a priority, force control and vision technologies enable high-precision picking without the need for custom-made trays. This reduces changeover costs while improving shop-floor adaptability and machining quality.
Applications
Flexible machine tending
The robot is equipped with a proprietary electric gripper featuring a compact design and adjustable stroke, gripping force, and opening/closing speed. These adjustments help prevent damage to precision parts and enable efficient loading and unloading.
Vision-guided picking and adaptive positioning
Vision-based guidance supports adaptive picking and positioning, including compliant pick-and-place operations involving very small clearances and rotational alignment.
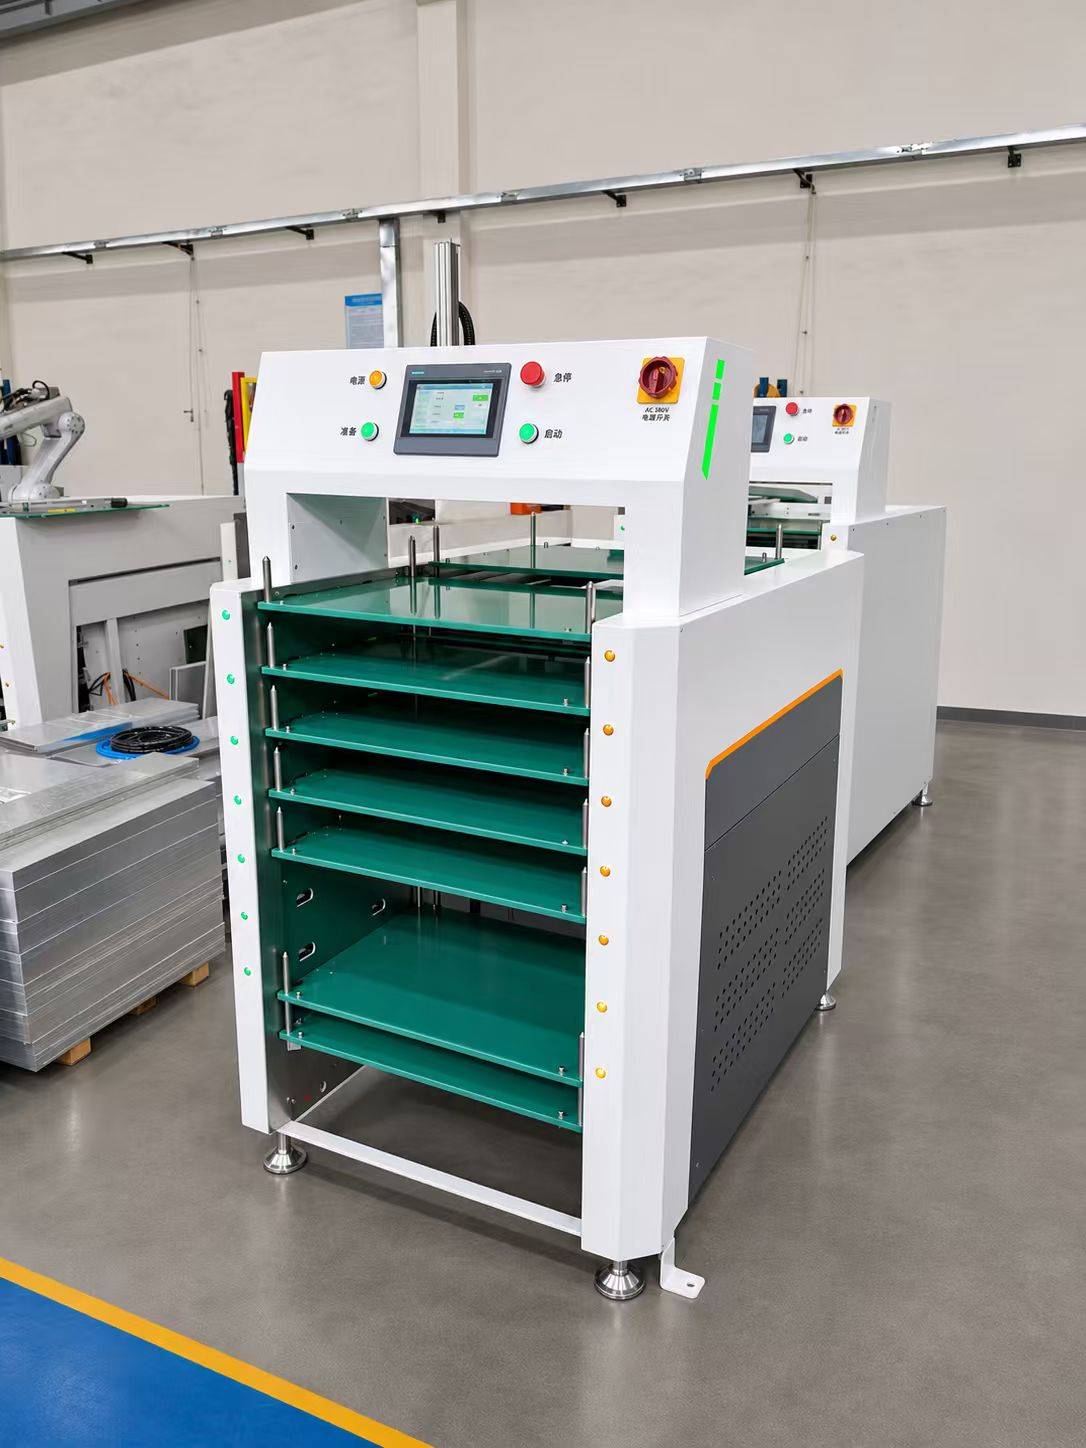
Intelligent tray management
Used with vision-guided flexible trays, the system accommodates a wide range of parts without requiring dedicated custom trays for each part type. This enables fast changeovers and eliminates the need for custom tray fabrication.
Human-robot collaboration
The workstation supports collaborative operation in a shared workspace. Force control functions, including collision protection and automatic alignment, help ensure safe operation.
No video available
Highlights
1
Force-controlled compliant loading
Supports compliant pick-and-place involving very small clearances and rotational alignment, as well as automatic alignment and collision protection.
2
Force control system
Force Control System: A proprietary six-dimensional force/torque sensor, a proprietary force control algorithm, a proprietary control system, and a proprietary electric gripper are designed to work together, ensuring system compatibility, stable operation, and efficient performance.
3
Flexible trays without custom tooling
Vision-based tray recognition eliminates the need to manufacture dedicated trays for each part type, significantly reducing changeover costs.
4
High-precision electric gripper
The proprietary electric gripper features adjustable stroke, gripping force, and speed to help prevent damage to precision parts.
5
Safe human-robot collaboration
Integrated force control technology supports collaborative operation in a shared workspace, helping enhance operational safety.
6
Machining-oriented software
Unlike conventional PLC-based operator interfaces, the software is designed around real-world machining workflows, with an emphasis on intuitive and convenient shop-floor operation. It is easy to learn and quick to reconfigure for new parts.
Have questions about this product?
Get in touch with us
Related Products